Multi-Drone LTL Formation Control
MATLAB simulations that pair continuous LQR tracking with temporal-logic specifications, covering region-based planning, formation switching and leader-follower flocking for a small drone fleet.
- Stack
- MATLABLQRTemporal LogicBüchi AutomataMulti-Agent Systems
Problem
Coordinating a fleet of drones needs two things that are usually studied separately. Each drone has to track a continuous trajectory accurately, and the fleet as a whole has to satisfy discrete requirements about where it goes and in what order, of the form “visit A, then B, and never enter C”.
Approach
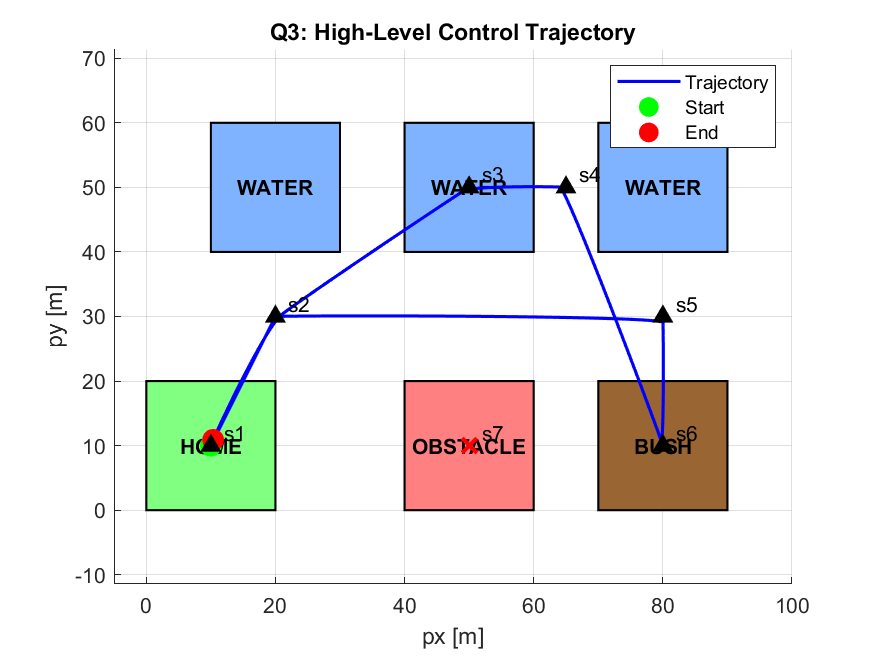
The continuous layer uses LQR tracking on a double-integrator drone model. The discrete layer abstracts the workspace into labelled regions and builds a transition system over them, then constructs Büchi and product automata so that an LTL-style specification can be checked and turned into a plan the continuous controller executes.
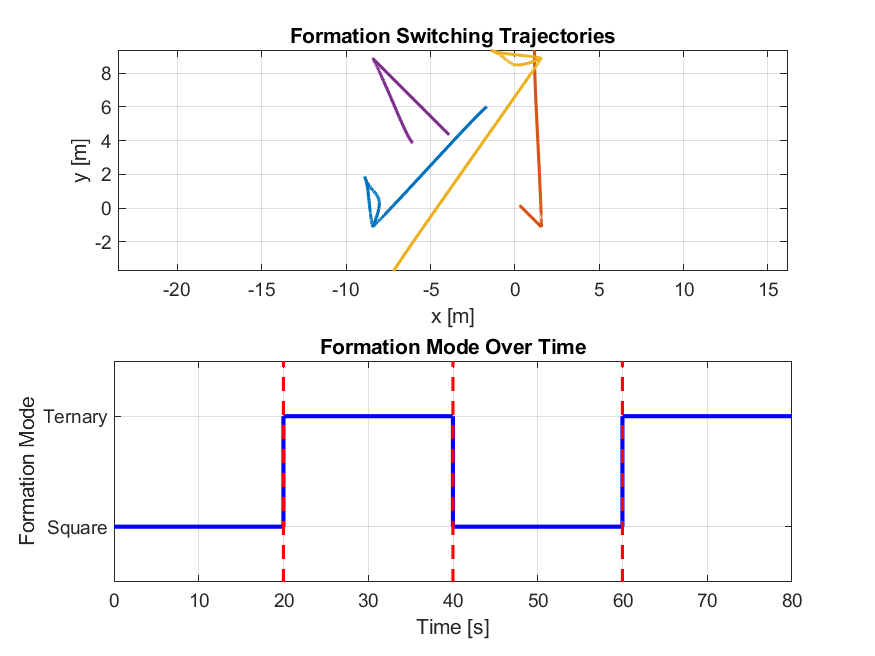
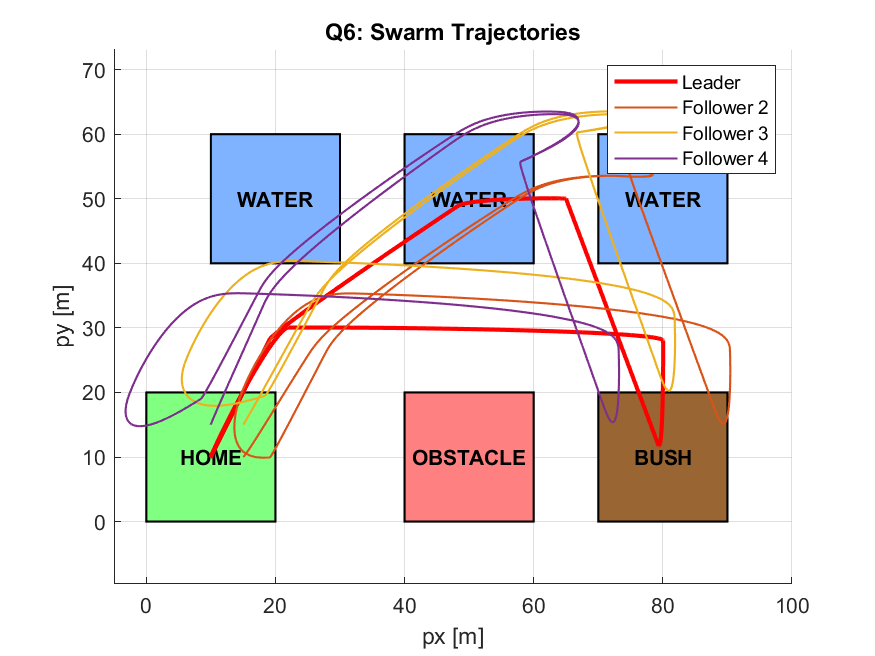
On top of that, the project implements formation controllers for square, ternary and switching formations, and leader-follower flocking with both straight and circular reference motion.
Scope
Everything here is simulation. The value is in demonstrating that the discrete planning layer and the continuous control layer compose correctly, not in representing a hardware deployment stack. No private data is involved.