Enterprise AI Document Risk Auditor
Document review grounded in evidence, with a human in the loop.
Work across AI systems, control and robotics, optimization and industrial data science. Each write-up covers the problem, the approach taken, and what the result does and does not show.
Document review grounded in evidence, with a human in the loop.
Agentic exploration of engineering design spaces, from models to decisions.
Three ways to give an agent its tools, compared with fifteen executed attacks.
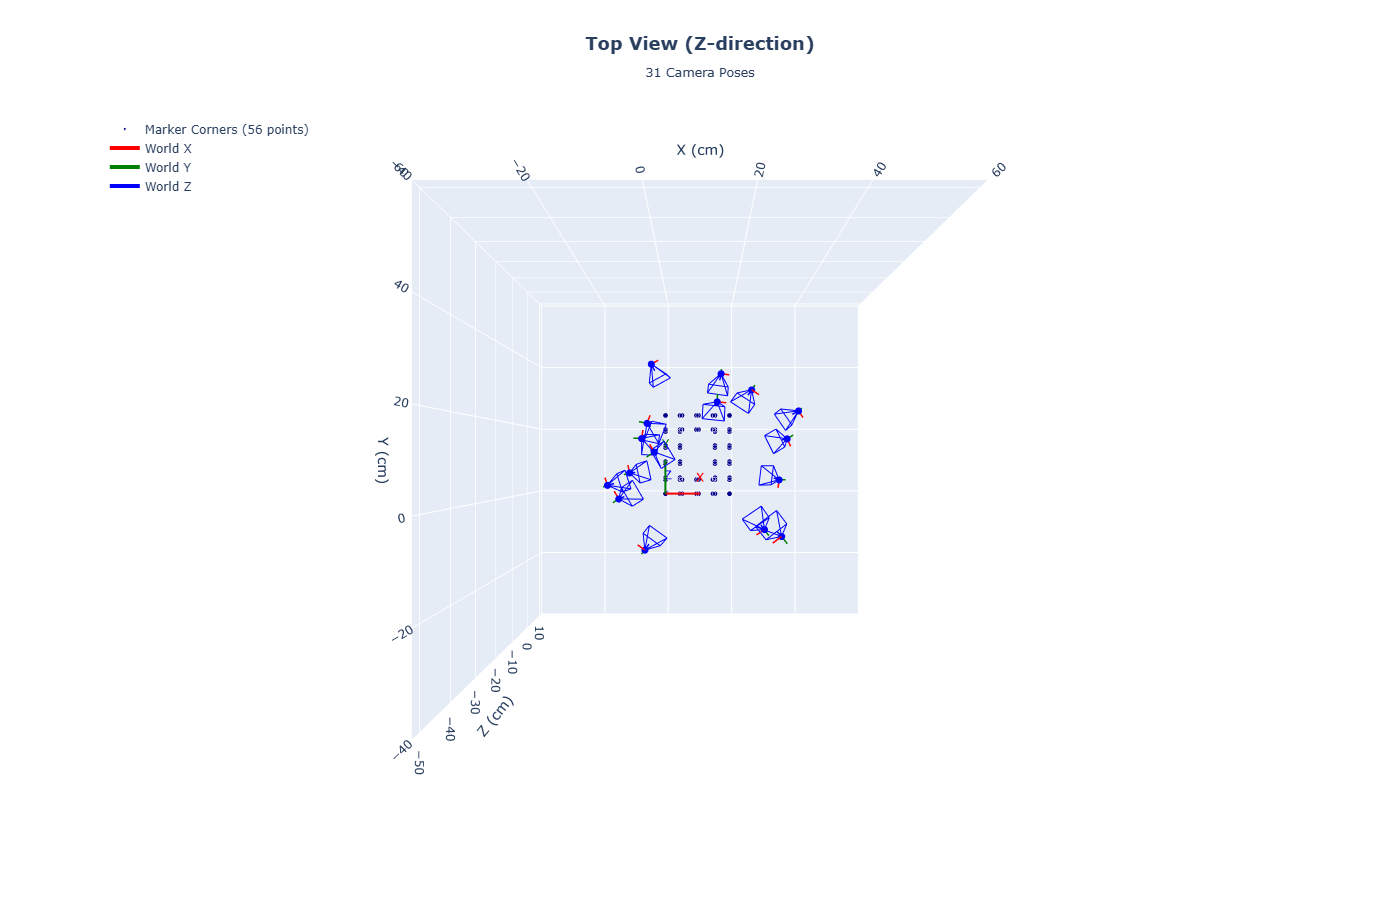
Python pipeline that calibrates a camera from an ArUco board, estimates poses, and converts them into the transforms NeRFStudio expects for 3D reconstruction.
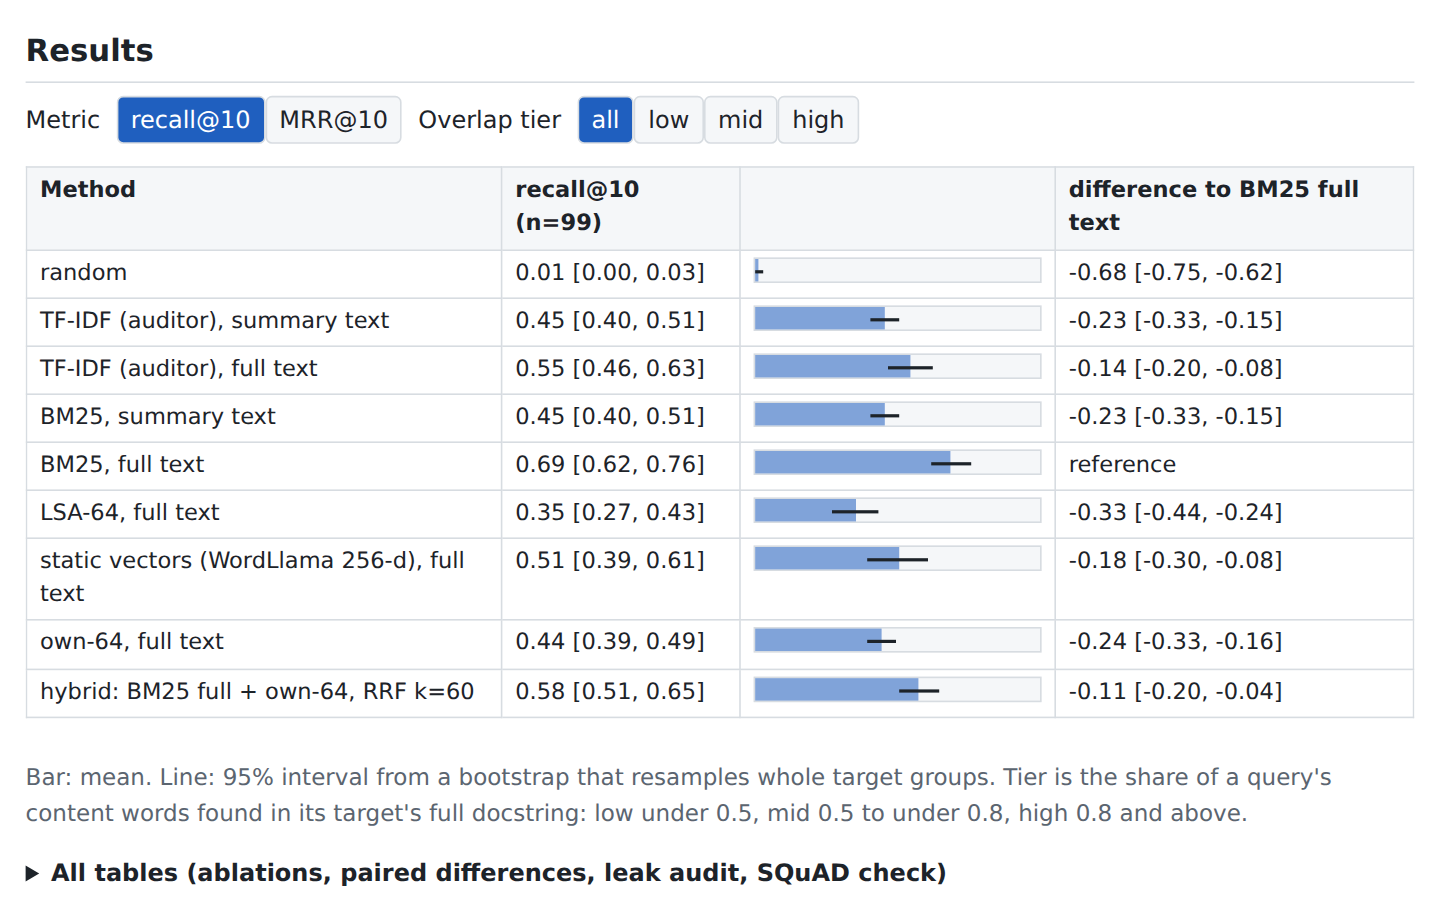
A 64-dimension embedding model trained from scratch in NumPy on NumPy and SciPy docstrings, compared with TF-IDF, BM25, LSA and static-vector baselines on the same text and queries; the trained model loses to BM25.
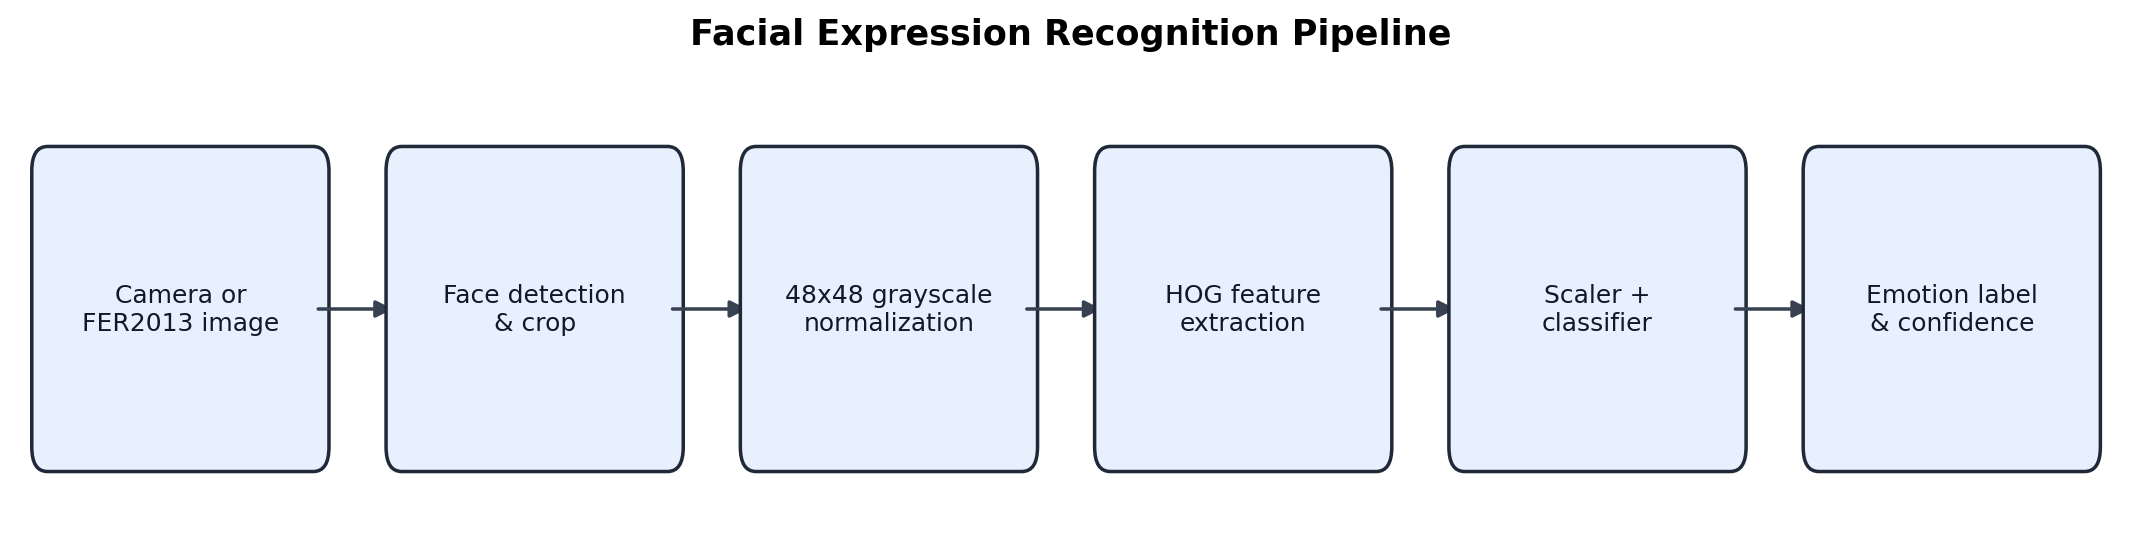
Computer-vision pipeline that detects a face, extracts HOG features and classifies it into seven expressions, built as a transparent classical baseline rather than a deep-learning system.
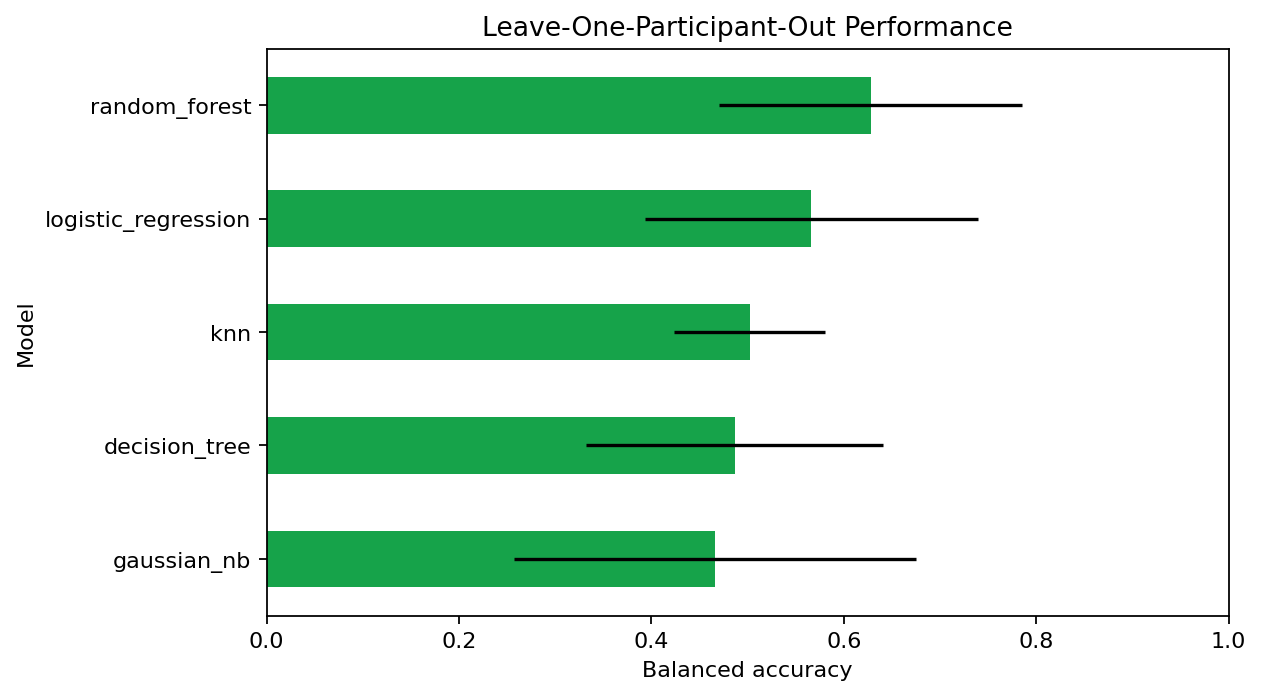
Classifies human activity from phone accelerometer and gyroscope signals, with participant-level validation that shows how far the model actually generalizes to people it has never seen.
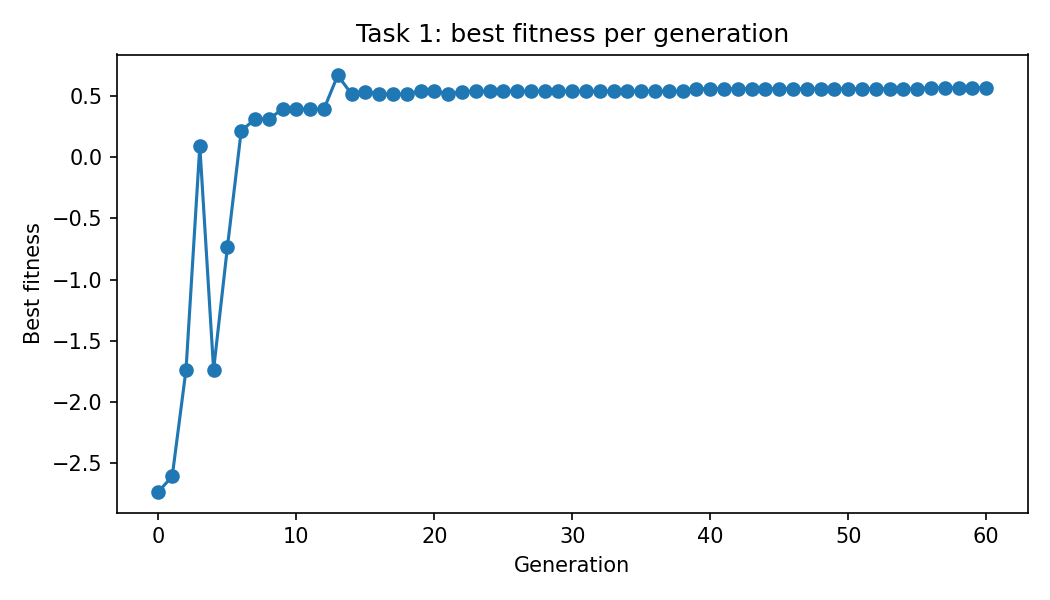
Evolves Petri-net structures from event-log traces with a genetic algorithm, comparing crossover, mutation and selection operators against a combinatorial search space.
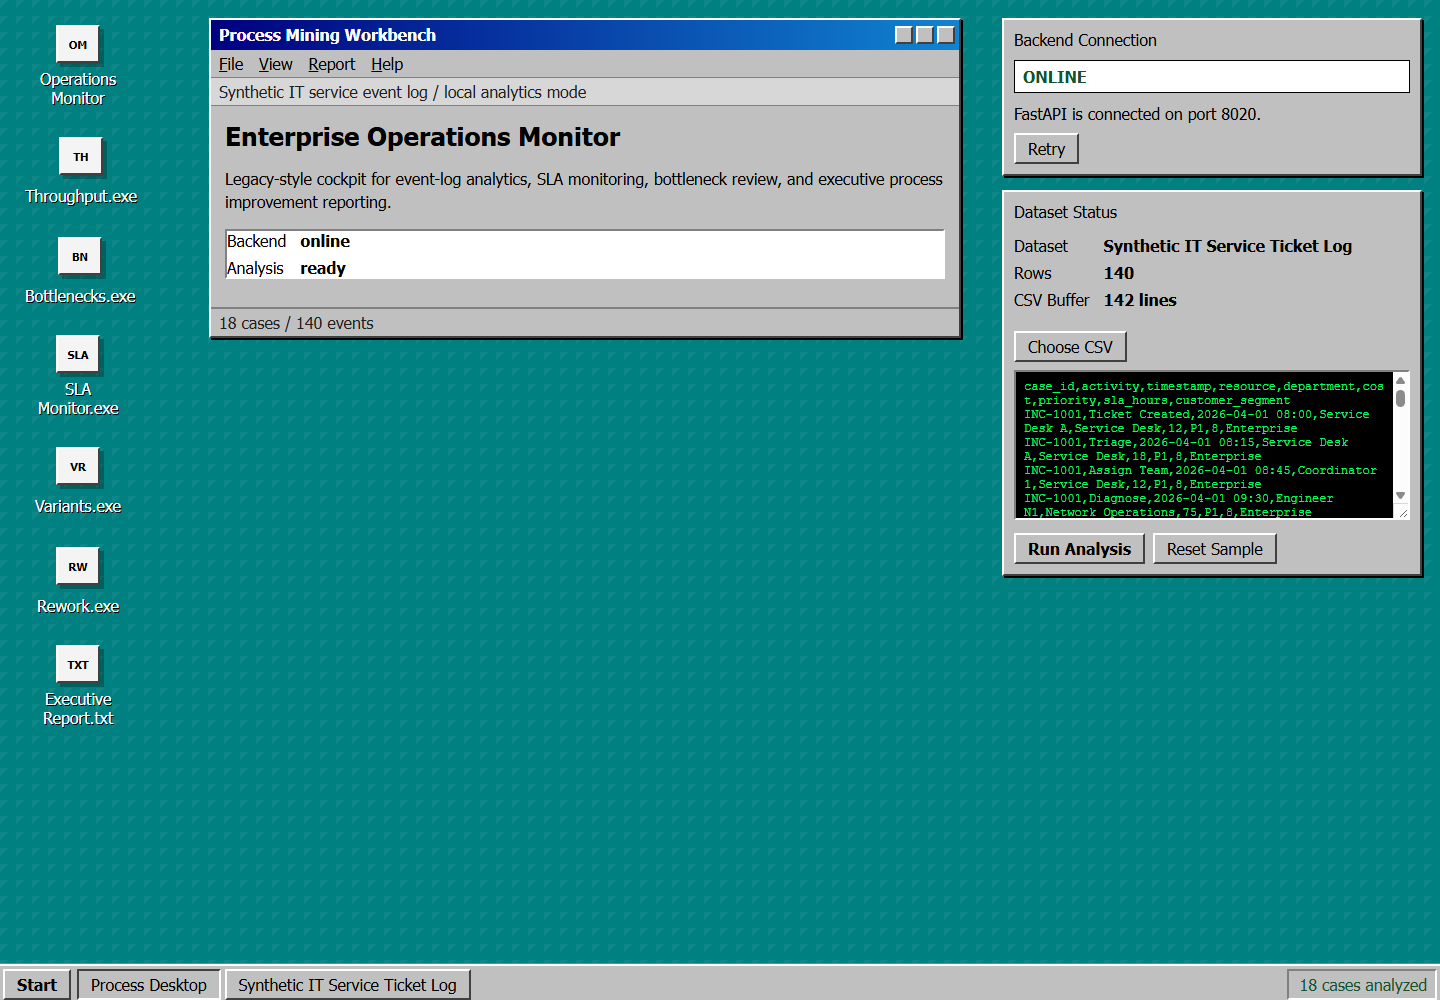
Local process-mining dashboard for IT service ticket event logs, covering SLA monitoring, bottleneck detection, variant analysis and executive reporting.
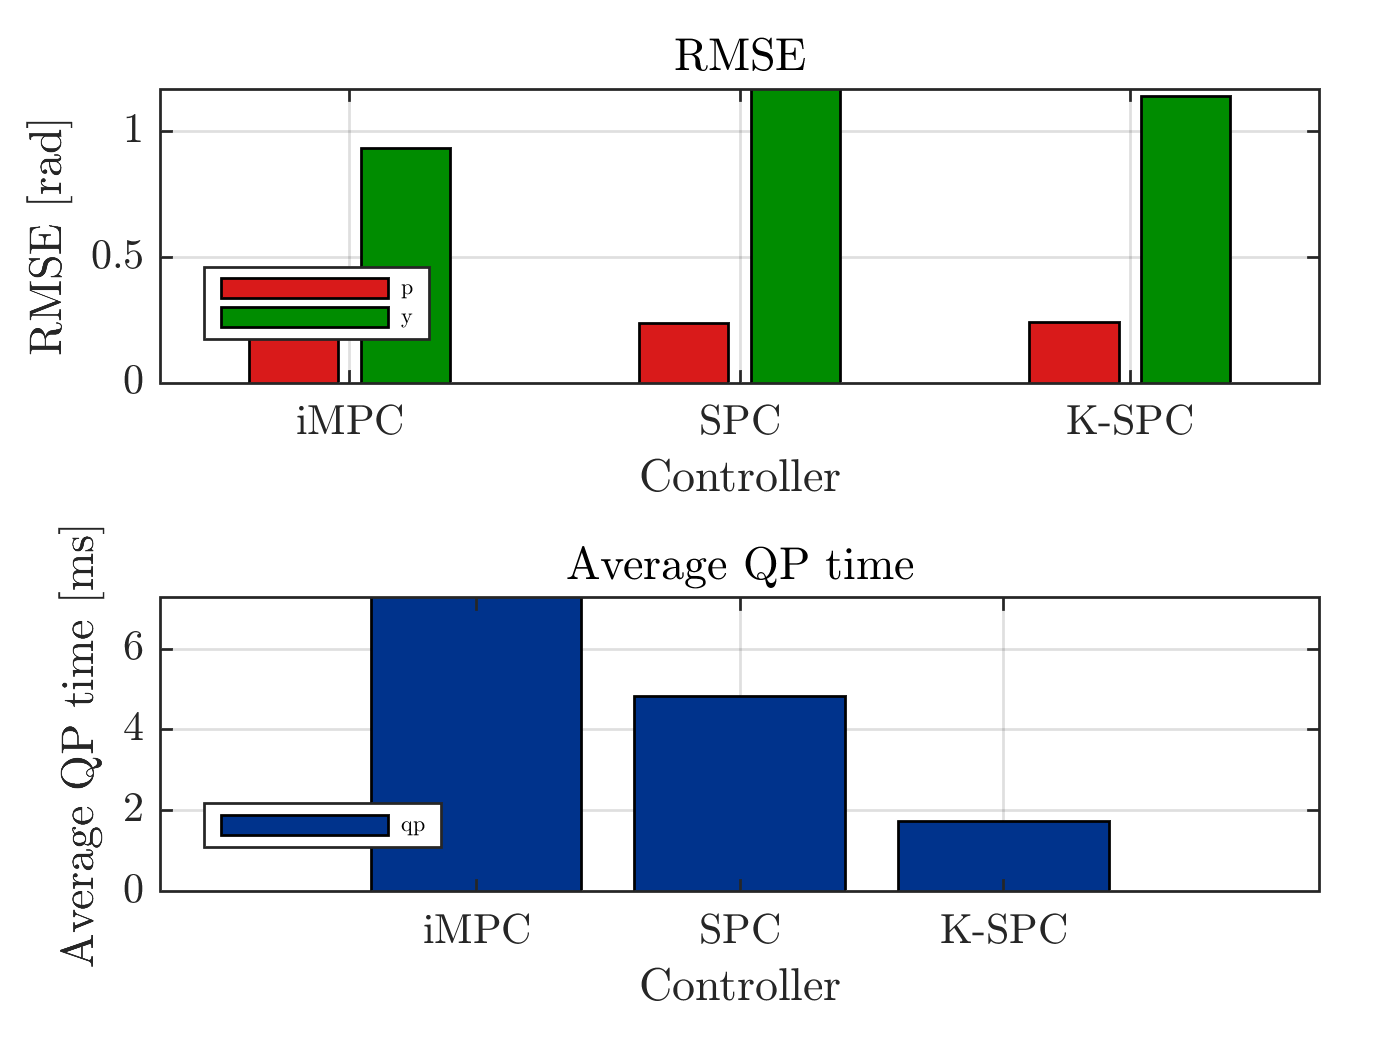
MATLAB benchmark putting linear MPC, iterative nonlinear MPC, subspace predictive control and Koopman-lifted SPC on the same pitch and yaw tracking problem under one evaluation workflow.
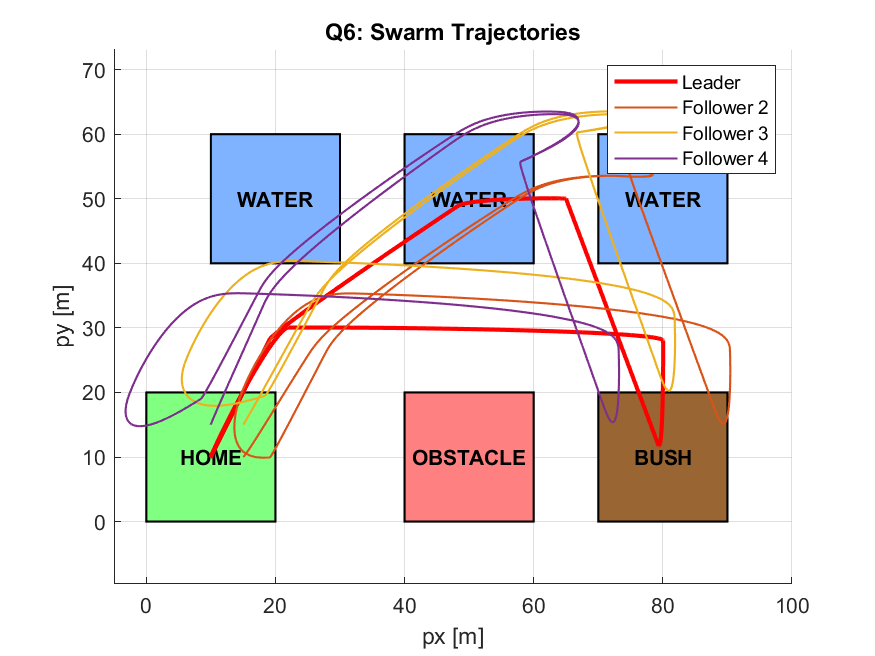
MATLAB simulations that pair continuous LQR tracking with temporal-logic specifications, covering region-based planning, formation switching and leader-follower flocking for a small drone fleet.